2D
Photos & drawings
Phone or robot-camera photos, walk-through video, floor plans and drawings.
JPGPNGHEICMP4MOVPDFDWGDXF
Real-to-sim conversion service
Photos, SLAM maps, floor plans or CAD in. A simulation-ready world out — USD, URDF or MJCF with metric scale, collision, physics and materials.
The gap
A photoreal splat or point cloud looks right, but a simulator can’t use it. Teams lose weeks re-modelling rooms by hand before the first test even runs.
Splats and point clouds have no solid floor or walls to drive on.
A chair is a cloud of points, not a part you can move or grab.
Planners and physics have nothing to avoid or push against.
Named parts, collision and physics — measured in your coordinates.
What we convert
2D
Phone or robot-camera photos, walk-through video, floor plans and drawings.
JPGPNGHEICMP4MOVPDFDWGDXF
SLAM
Occupancy maps from your AMR, lidar point clouds, recorded rosbags.
PGM+YAMLPCDPLYLAS/LAZE57BAGMCAP
3D
CAD, meshes, photogrammetry and Gaussian splats.
STEPSTLOBJFBXGLB/glTFUSDSPLAT
YOU GET
USD / USDZURDFMJCFSDFGLB
Proof
These are internal MATRIX lab demos, recorded on our own robots and sites — not customer results. We show the numbers so you know what we measure.
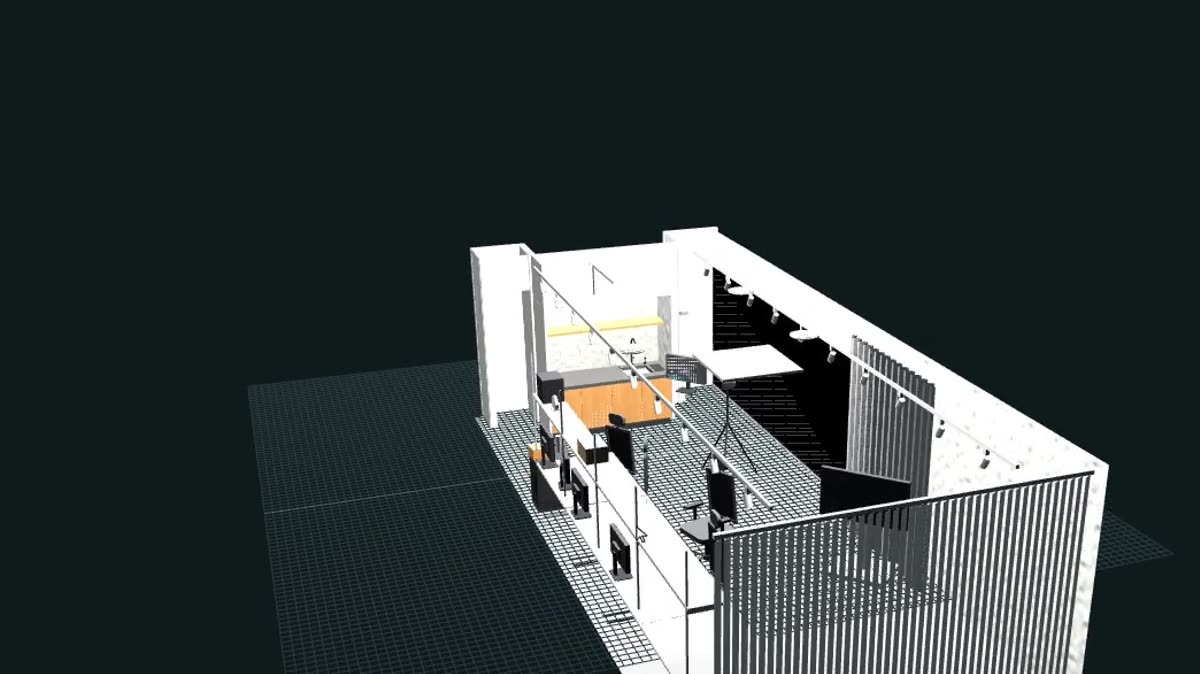
CASE 01 · PHOTOS → ASSET
Two robot arms scanned the room with their wrist cameras. We rebuilt it as a Gaussian splat, then as CAD parts placed in the robots’ own frame — with textures, lights and collision.
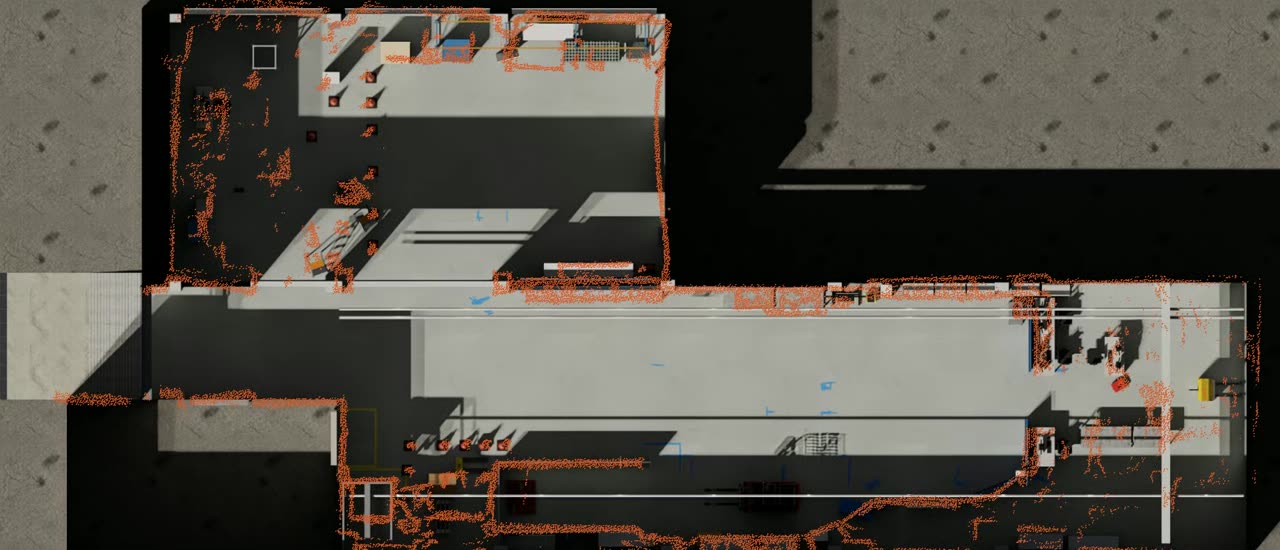
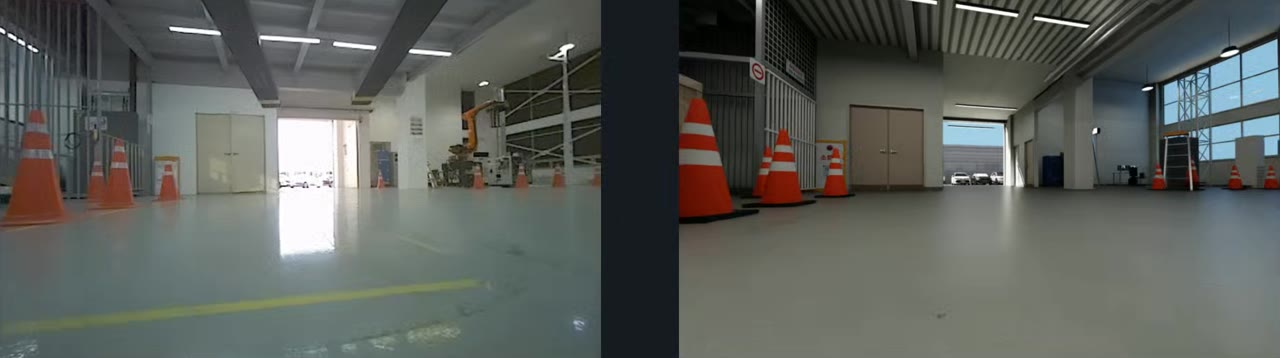
CASE 02 · SLAM MAP + FLOOR PLAN → TWIN
We aligned the AMR’s own map to the building floor plan, then checked the twin against the real forklift’s camera at the same pose. The vehicle model came from one parameter file.
How it works
Drop files or paste a link. Tell us which simulator you use.
An engineer replies with questions, scope and an NDA if you need one.
A sim-ready sample of your space to open in your own simulator.
The full package, revised until it loads and behaves the way you need.
Free pilot
One space up to 300 m², or one robot / vehicle. No card, no commitment. If the sample is useful, we’ll quote the rest.
Prefer email? admin@steerix.ai
✓
An engineer will reply to within 24 hours with scope and any questions. A confirmation email is on its way.
Ref
FAQ
Files go to private cloud storage that only our team can open. We use them only for your conversion and won’t show or reuse them without your written permission. Want an NDA first? Email admin@steerix.ai before uploading.
It loads in your simulator at real scale, with separate named parts, collision shapes, physical defaults and materials — so robots can drive, plan and collide in it, not just look at it.
We deliver USD (Isaac Sim / Omniverse), MJCF (MuJoCo), URDF / SDF (ROS, Gazebo) and GLB (Unity, Unreal, web). Tell us your setup and we’ll match it.
Up to 500 MB per file on this page. For larger data — long rosbags, full-site scans — paste a Google Drive, Dropbox or WeTransfer link.
Send what you have. Within 24 hours we’ll tell you what’s missing — often a few extra photos or a floor plan is enough.
It depends on size and detail. After the free sample we send a fixed quote per space or asset, so there are no surprises.